I design and build robotic systems, from mechanical design and fabrication to embedded control and simulation.
Graduate Researcher · Creative Machines Lab, Columbia University
Currently building: spherical robots
I designed and analyzed modular airframe components using SolidWorks and FEA.
Validated critical load paths above a 2.0 factor of safety.
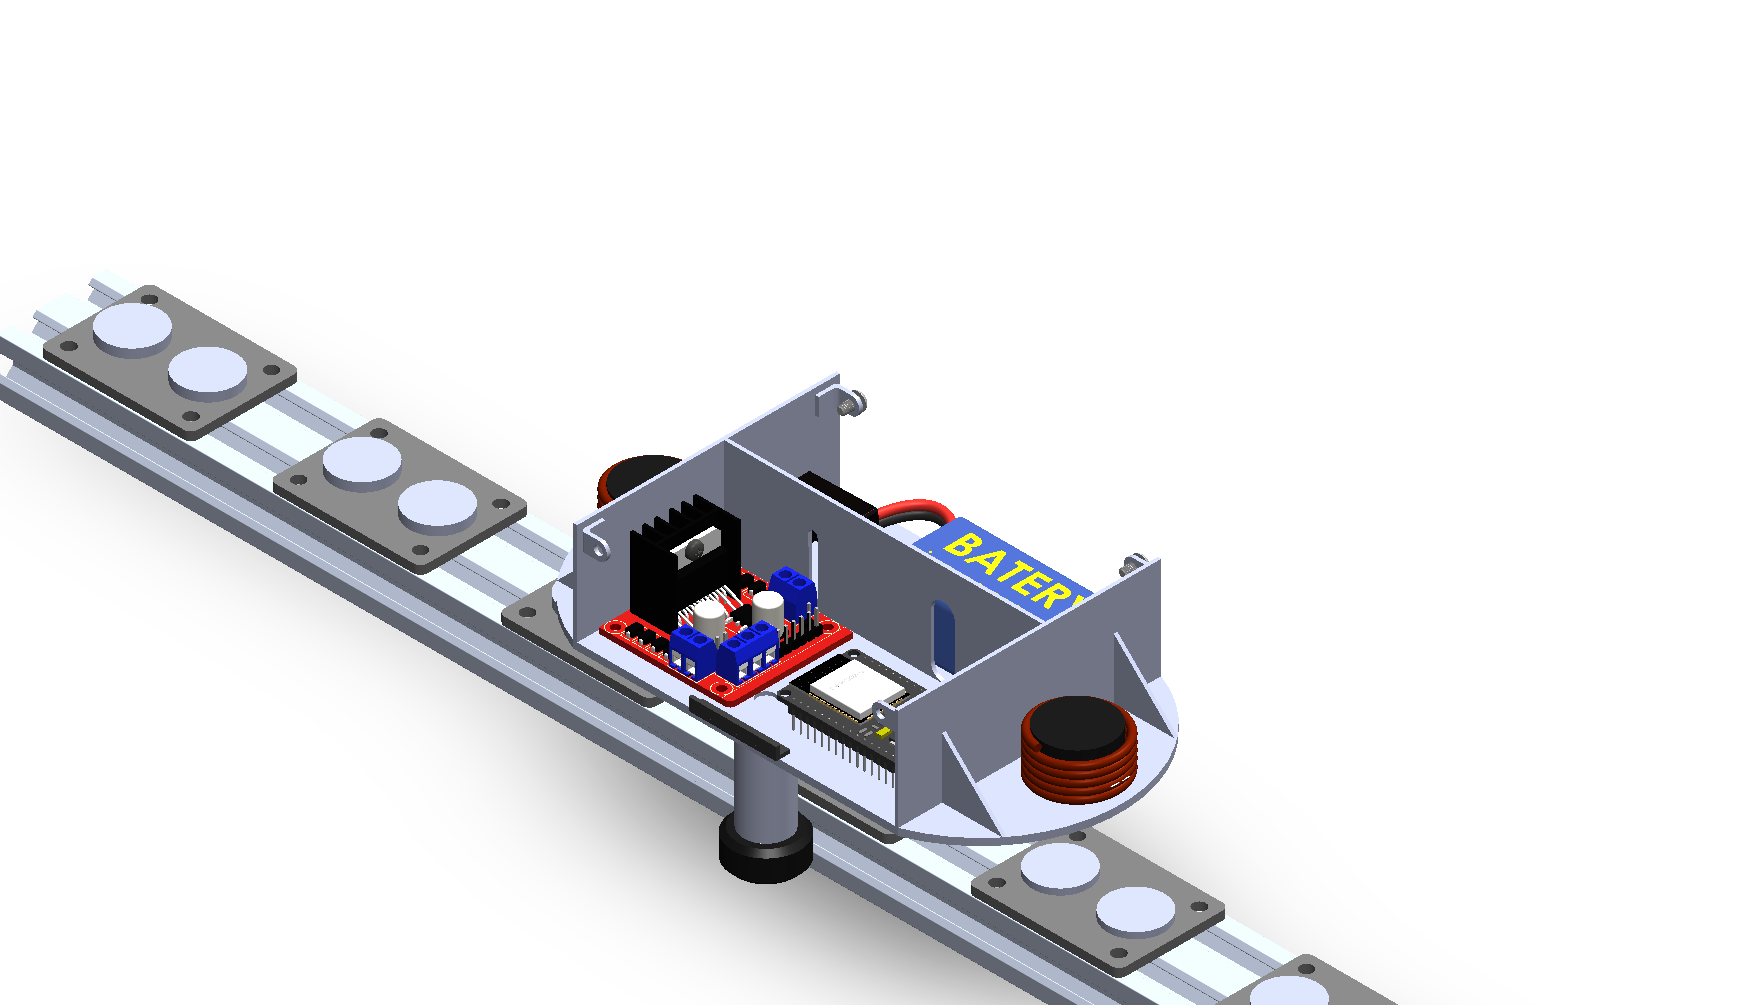
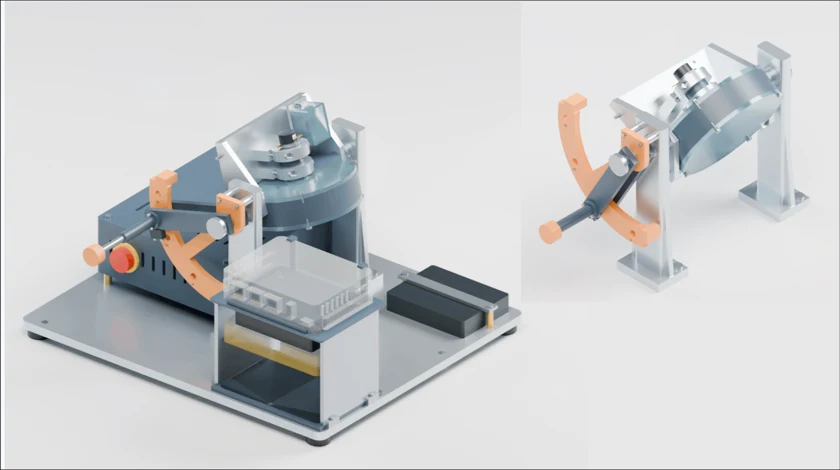
I led electronics, Arduino firmware, and PID tuning for a team-built four-bar mechanism.
Achieved ±10° control precision within a $100 material budget.
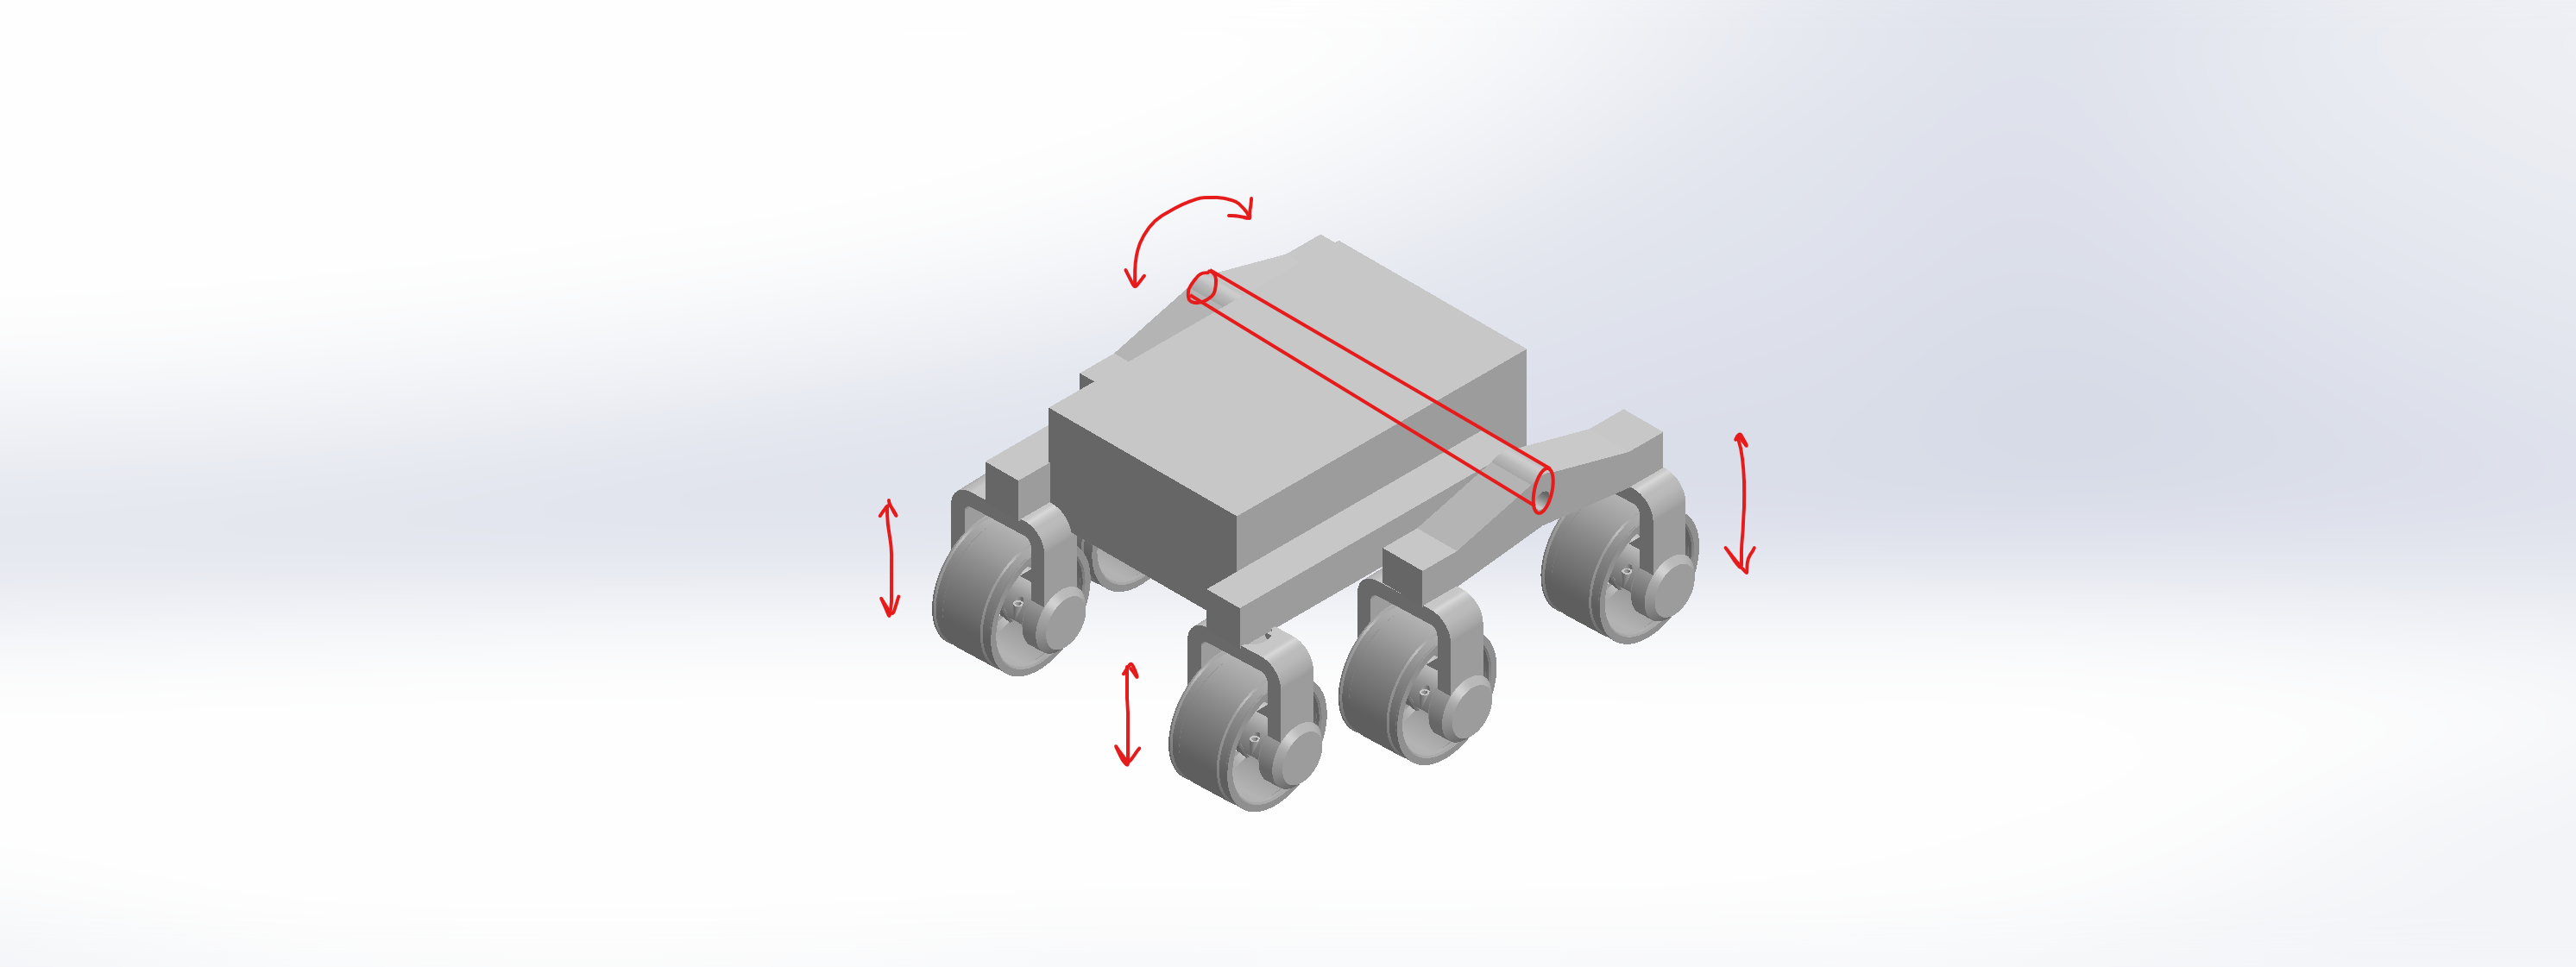
I built the CAD-to-URDF model and a ROS2 swerve-drive controller.
Validated four drive modes across RViz2, Gazebo, and Isaac Sim.
I co-led the program and owned mechanical architecture, CAD, and chassis fabrication.
Delivered a fabricated test chassis and a complete core-drill design.
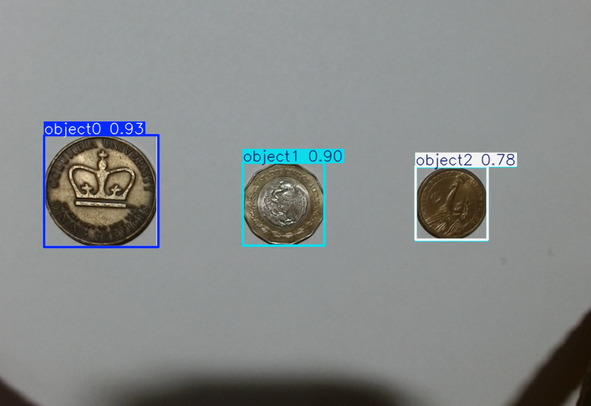
I fine-tuned object-segmentation models and connected detections to inverse-kinematics targeting.
Streams object coordinates into a 10 Hz control loop.
Designing and prototyping a hybrid tendon and direct drive robot hand.
Designing and prototyping spherical robots with compact motorized drivetrains, embedded control, and sensing. Developing an Isaac Sim digital twin with compliant shell dynamics for reinforcement learning and coordinated behavior across 50 sphere robots.
Help students learn torque calculations, gear reduction selection, transmissions, linkage synthesis, PID tuning, and electronics. Machine and waterjet parts to prepare student project kits, and hold office hours to review concepts and homework questions.
Build simulation-ready digital twins in Gazebo and Isaac Sim. URDF/Xacro modeling, controller configuration, action graphs for ROS2 integration.
Managed aerospace autoclave projects from design to commissioning. Designed ASME-compliant pressure vessels with Compress and ANSYS Workbench FEA, and created process/instrumentation drawings and fluid flow simulations.
Designed robotic exoskeleton components for cerebral palsy rehabilitation.
Led the mechanical design and fabrication work for NASA Lunabotics, managing a 17-person multidisciplinary team. Conducted materials research and FEA on 3D-printed TPU structures and LM-1 regolith simulant.
Refactored AutoBagger to boost output 4×. Integrated autonomous robots and conducted safety audits.
Engineered liquid desiccant HVAC systems using NX CAD. Supported rapid prototyping and iterative experimental design. Hired, paid, and managed by Emerson while the division transitioned to Copeland; work spanned both brands.
Created tools and infrastructure to increase throughput by 30%. Automated inventory management and optimized factory layout.
Redesigned drivetrain for reduced weight and enhanced durability. Led thermal testing and mechanical analysis.
Taught 20 STEM students and created a 1-week engineering curriculum. Mentored student teams.
Led aqueduct design for a Nicaraguan community. Served as translator and liaison with local engineers.
Hi, I'm Emiliano — a first-year Robotics & Controls M.S. candidate at Columbia University. I'm driven by a passion for building technically rigorous robotics and automation systems that have a meaningful, positive impact on society.
I earned a Bachelor of Science in Mechanical Engineering from Columbia University. Currently, I'm a robotics researcher in the Creative Machines Lab and the ROAM Lab at Columbia. At the same time, I'm also consulting in robotics simulation, mechanical design, and manufacturing engineering in the startup space. My professional experience spans multiple industries and engineering disciplines, which I seek to apply to a career in robotics.
I'm hands-on by nature, whether I'm designing parts, improving processes, or integrating systems. I take pride in learning fast, adapting quickly, and always asking how something can be made better.
If you're working on something cool — let's talk.
Ready to solve
meaningful problems
together?